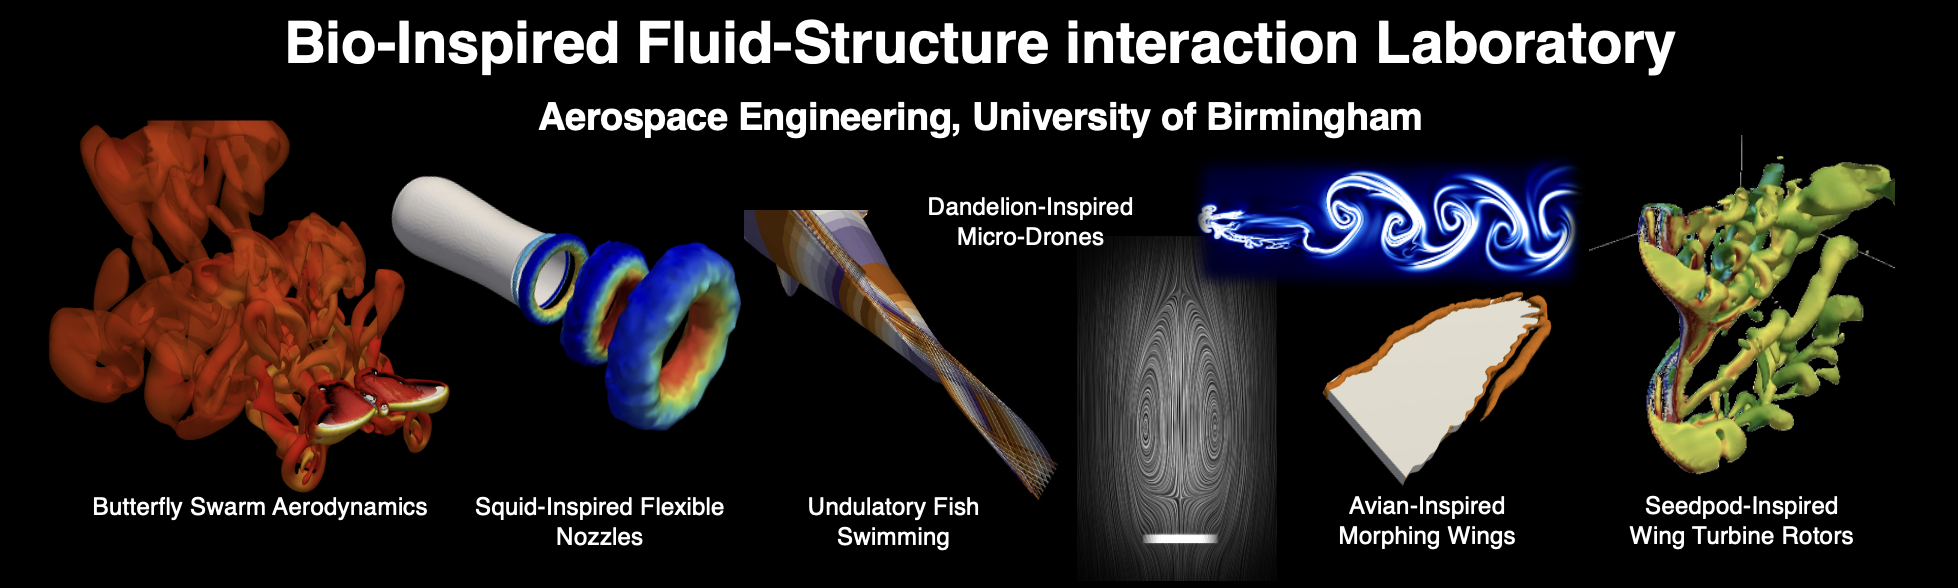
Funded Projects
Fellowships, research grants and computing allocations supporting the BioFSI Lab: 19 awards in total, all led by Dr Chandan Bose as Principal Investigator, including £348k in UK and international grants and €155k in European fellowships and funding. 6 projects are currently active.
Funded by
International Collaboration Grants
The Scheme for Promotion of Academic and Research Collaboration (SPARC) with IIT Kharagpur Active
|
ProjectSimulating Nature in Exa-Scale: GPU-Accelerated Fluid-Structure Interaction Modelling of Bio-Inspired Drone Swarms
|
Going Global - Springboard Programme with Max Planck Institute, Germany Active
|
ProjectInvestigating Collective Flight & Swimming For Bio-Inspired Robotics
|
IIT Madras–University of Birmingham Partnership Collaboration Award Active
|
ProjectUncertainty-Aware Optimisation of Fluid-Structure Interaction Systems Using Bayesian Optimisation and Gaussian Process Surrogates
|
International Exchange Grant with IIT Kharagpur, India Active
|
ProjectDevelopment of a Multi-GPU Fluid-Structure Interaction Solver for Simulating Bio-Inspired Flapping Flight
|
Going Global - Springboard Programme with ESPCI Paris, CNRS, France Completed
|
ProjectWave Energy Conversion through the Wave-Structure Interaction of Bioinspired Flexible Membranes
|
EuroMech Colloquium Funding Completed
|
ProjectColloquium on Bio-Inspired Fluid-Structure Interaction
|
UK-France Collaborative Seed Funding Completed
|
ProjectVortex-Dominated Flow Physics of Bio-Inspired Porous and Flexible Structures
|
Seed Grants
Institute of Data and AI Pump Priming Collision Grant Completed
|
ProjectDeepSight: Data-Driven Early Detection of Glaucoma and Virtual Surgery Modelling
|
COSIMO Network+ Seedcorn Grant Completed
|
ProjectDeepSight: Smarter Glaucoma Detection via Spatio-Temporal Deep Learning
|
Impact Acceleration Account Funding Completed
|
ProjectOpen-Source Code and Software Impact Pathways
|
Fellowships
CoSeC Fellowship – 2025 Cohort Active
|
ProgrammeComputational Science Centre for Research Communities (CoSeC) Fellowship Programme: ambassador for CoSeC and the Collaborative Computational Project (CCP) model of research software development, support and training across UKRI
|
Chargé de Recherches - FNRS Post-Doctoral Fellowship Completed
|
ProjectNumerical and Experimental Investigation of Three-Dimensional Dynamic Stall at Low to Moderate Reynolds Numbers: Prediction and Control
|
Wallonie Bruxelles International Excellence Post-Doctoral Fellowship Completed
|
ProjectNumerical and Experimental Investigation of the Non-Linear Fluid-Structure Interaction Dynamics of Flapping Wings in Turbulent Flows
|
Computational Time (HPC) Grants
National and university supercomputing allocations (ARCHER2, Cirrus via EPSRC Access to HPC, and Baskerville) that power the lab’s high-fidelity fluid–structure interaction simulations — 5 awards, including 9.8 million CPU hours on Cirrus.
| Project | Funder | Award | Period | Role | Status |
|---|---|---|---|---|---|
| Access To HPC GrantWave propagation and impulse enhancement in squid-inspired flexible nozzles subjected to rotary wake | EPSRC | £37k9,830,400 CPUh on Cirrus | 2026 – 2027 | PI | Active |
| Baskerville HPC GrantGPU-Accelerated Solver Development for Simulating Butterfly Swarms | University of Birmingham | £35k | April 2025 – January 2026 | PI | Completed |
| Archer2 Pioneer GrantInvestigation of Bio-Inspired Multi-Phase Fluid-Structure Interaction Problems | EPSRC | £70k | 2023 – 2026 | PI | Completed |
| Access To HPC GrantFlight dynamics of free-falling three-dimensional porous bodies subjected to stochastic transverse gustsCo-investigator: Dr. Ignazio Maria Viola, Reader, School of Engineering, University of Edinburgh | EPSRC | £30k | 2023 – 2024 | PI | Completed |
| Access To HPC GrantFluid-Structure Interaction and wake dynamics of dandelion seed flight under gustCo-investigator: Dr. Ignazio Maria Viola, Reader, School of Engineering, University of Edinburgh | EPSRC | £28k | 2022 – 2023 | PI | Completed |
Earlier Projects
Innovative Project Grant, IIT Madras Completed
|
ProjectDesign, Fabrication and Aerodynamic Testing of a Bio-Inspired Flapping-Morphing Wing Micro Aerial Vehicle
Read moreShow lessIn this project, we fabricated a single-wing desktop flapping set-up and experimentally tested it in the low speed wind tunnel of the Biomimetics Laboratory, Dept. of Aerospace Engineering, IIT Madras to measure the aerodynamic loads generated by three different rigid and flexible flapping wings using a 6-dof force/torque sensor. Lift forces were measured for different flapping frequencies and wind speeds. Increase in the inflow velocity was seen to result in a gradual decrease in lift forces for the rigid wing; whereas the lift first decreased and then increased for the flexible wings. An increase in the flapping frequency always resulted in higher lift forces. The flexible wings significantly outperformed the rigid wing at higher flapping frequencies. The effect of a time harmonic gust on the aerodynamic performance was also investigated in this study. The lift forces generated by the rigid wing was seen to be significantly reduced with the increase in the gust frequency ratio, whereas the flexible wings could overcome this effect. Also, the effect of gust was observed to become dominant at low mean flow speeds. Learning from these outcomes, we designed a four-wing radio-controlled flying model (with flapping and morphing) and tested its aerodynamic performances in the presence of uniform as well as gusty inflows. It was seen that at a higher flapping frequency, its flexible wings could completely alleviate the effect of the gust and the lift force was seen to be increased due to the interaction of the wing flexibility and the gusty fluctuations. However, the generated lift force was still not sufficient to overcome the self-weight of the flying model. Relevant Publication
|